
CSS CANmod.gps
GPS to CAN with 3D Inertial Sensor and UDR

This standalone GPS-to-CAN module produces GNSS position and 3D inertial data (via a gyroscope and accelerometer) and outputs it via configurable CAN bus frames.
The module supports 'Untethered Dead Reckoning', meaning that even if the GNSS signal is lost entirely, the module can deliver continuous positioning through IMU-based estimates (no external inputs required).
Customer can integrate the module with any CAN bus, e.g. vehicle networks or CAN hardware. As an example, Customer can use it as a plug and play add-on module for the CANedge.
The Antenna is Included.

Position - enhanced by 'sensor fusion'
The module outputs 1 Hz position and satellite status. It supports GPS/Galileo/BeiDou/GLONASS and uses sensor fusion to deliver high precision with UDR support (Untethered Dead Reckoning).

Speed
Speed data is useful in e.g. fleet telematics to identify speeding, idle time, asset utilization rates and more.

Altitude
Altitude can be a key parameter in e.g. the analysis of fuel/battery consumption in a vehicle - or e.g. in aerospace applications like drones, planes etc.

Attitude (roll, pitch, heading)
The CSS CANmod.gps uses GNSS/IMU sensor fusion to provide attitude data, enabling a complete 3D picture of the asset orientation at any given time (for automotives).

Odometer (distance since power on and total)
Odometer data enables easy tracking of the distance travelled by the asset - both in total (since reset) and per trip (since last module power cycle).

3D IMU: Angular Rate
The 100 Hz angular rate data can be used in e.g. the analysis of driving behavior and vehicle dynamics (tire/suspension, turning, drifting, ...).

3D IMU: Acceleration Rate
The 100 Hz acceleration data can be used in e.g. analysis of road/driving quality (speed bumps, harsh braking, ...) and predictive maintenance.

Geofences
The module can output the status of configurable circular geofences at 1 Hz - useful for e.g. theft prevention, safety improvements, process automation and more.

Timestamps (epoch data and time)
The CSS CANmod.gps outputs a high precision epoch timestamp - useful in providing historical date/time for the GNSS/IMU data and e.g. syncing the internal time of connected CAN hardware.

Easy add GNSS/IMU Data to any CANBus System
CSS CANmod.gps makes it easy to add position and 3D inertial data to your CAN bus - e.g. for use by ECUs or CAN hardware.
- Compatible with any high speed CAN bus (2.0A, 2.0B)
- Fully configure CAN IDs, bit rate and message frequency
- Power at 5-26 V DC via standard DB9 adapter cables
- Optionally record the data via any CAN interface/logger
- Use as add-on for the CANedge (power via 2nd port)
- DBC file included for easy decoding to human readable form
- White label e.g. for inclusion in your production

CSS CANmod.gps comes with a 3-meter GPS antenna with magnet foot and 4 status LEDs 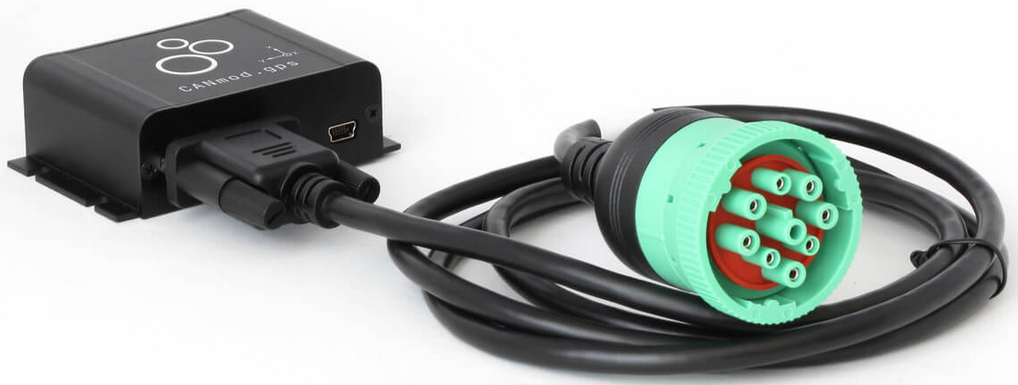
Customer can install the CANmod.gps 'standalone' in any CAN system (cars, trucks, ships, …) to transmit configurable CAN frames with GNSS/IMU data into the existing CAN traffic 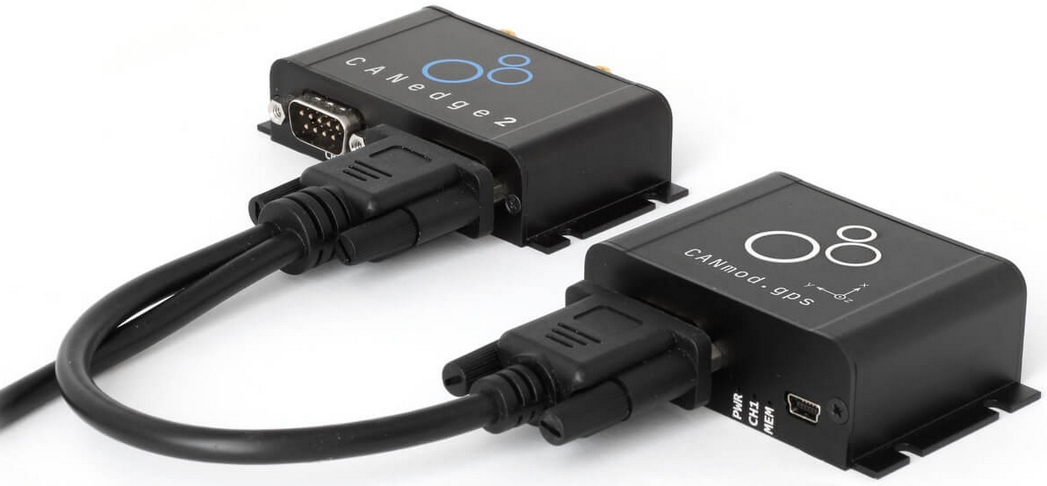
CSS CANmod.gps module can e.g. be used as a plug & play add-on for the CANedge (powered via 2nd port) - letting you combine CAN/LIN data with timesynced GNSS/IMU data 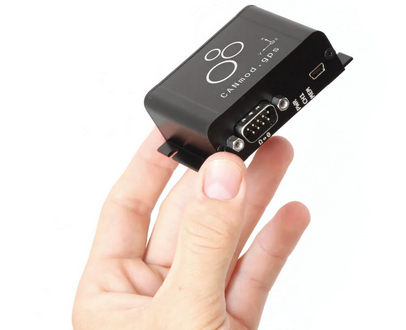
CSS CANmod.gps offers vast functionality and pro specs - yet it is extremely compact, measuring only 7 x 2 x 5 CM and weighing just 70 G 
If you deploy the CSS CANmod.gps to output data directly into your CAN bus, the data can e.g. be used by other ECUs on the network 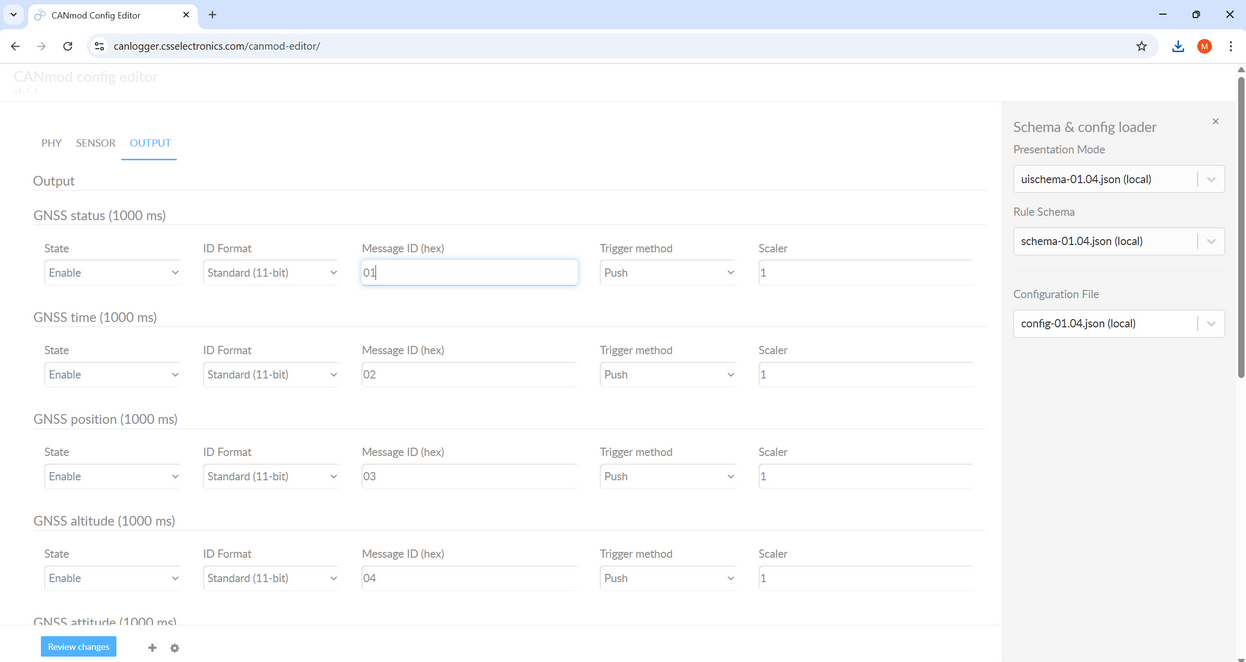
CSS CANmod.gps can be configured via the USB connector using our online/offline config editor tool (or a simple JSON text editor)

Add GNSS/IMU Data to your CANedge Log Files
Easy enhance your CANedge2 CAN/LIN data with GNSS/IMU information by connecting the CANmod.gps to the 2nd port.
Technical Specifications
| General | |
|---|---|
| Functionality | The configurable device produces GNSS/IMU data and outputs it via CAN bus and/or USB |
| Included | CANmod.gps module, u-blox GPS antenna and USB dust cover (mini USB adapter not included) |
| Firmware | Supports free firmware updates via USB for adding features |
| Configuration | Configuration files based on the popular open source JSON schema concept (similar to the CANedge) |
| Software | Free open source editor tool for easy device configuration (offline/online version available) |
| Safety | CE, FCC, IC and RoHS certified (see the Docs for certificates) |
| Warranty | 1-year warranty |
| Support | Free, fast & high quality support |
| Support period | Security updates & vulnerability handling for min. 5 years from purchase (EU CRA) |
| Origin | Denmark |
| Sensor (GNSS/IMU) | |
|---|---|
| Module | Professional-grade-u-blox-NEO-M8U (72-channel) sensor with built-in gyroscope and accelerometer |
| GNSS | Supports (combinations of) GPS (USA), Galileo (Europe), BeiDou (China), GLONASS (Russia) |
| Geofences | Supports 0-4 configurable circular geofences (status sent via CAN bus) |
| Sensor Fusion (UDR) | Enhanced position precision via sensor fusion (UDR) of GNSS and 3D IMU (automotives only) |
| Acquisition | Cold starts: 26s / Aided starts: 3s / Reacquisition: 1s |
| Sensitivity | Tracking/Navigation: 160 dBm / Cold starts: 148 dBm / Hot starts: 157 dBm |
| Battery Backup | The module has a battery backup to enable 'aided starts' (3s) between power cycles |
| Accuracy | Position: 2.5 m CEP (Circular Error Probable) |
| Heading: 1 degree (50% at 30 m/s) | |
| Velocity: 0.05 m/s (50% at 30 m/s) |
| Data Parameters | |
|---|---|
| CAN Signals | The module communicates several GNSS/IMU signals (for a full list, see the Docs or DBC file) |
| GNSS position: Longitude and latitude information [1 Hz] | |
| GNSS time: Precise GNSS based epoch timestamp [1 Hz] | |
| GNSS status: Fix type (No/UDR/2D/3D/GNSS+UDR) and satellite count [1 Hz] | |
| GNSS speed: Travel speed in meters/second [1 Hz] | |
| GNSS altitude: Altitude information in meters [1 Hz] | |
| GNSS attitude/orientation: Roll, pitch, heading [1 Hz] | |
| GNSS odometer: Distance traveled (since power on and total) [1 Hz] | |
| 3D IMU: Gyroscope-based angular rate (X, Y, Z) and accelerometer-based acceleration (X, Y, Z) [100 Hz] | |
| Geofences: Status of the configured geofences [1 Hz] |
| CAN Bus | |
|---|---|
| Channels | 1 x CAN channel |
| Modes | The device can either broadcast the data onto the CAN bus - or provide it on-request |
| Standard | ISO 11898: Compliant with CAN (up to 1 Mbit/s) |
| Identifiers | Compliant with CAN specifications 2.0A (11-Bit ID) and 2.0B (29-Bit ID) |
| Termination | Termination can be toggled via switch below DB9 connector |
| Retransmission | Retransmission of frames that have lost arbitration or been disturbed by errors |
| Transceiver Protection | Protection: +/- 25kV HBM ESD, +/- 12kV IEC ESDm +/- 14V bus fault, short circuit |
| Common mode input voltage: +/- 12V | |
| TXD dominant timeout (prevents network blocking in the event of a failure) |
| Configuration | |
|---|---|
| Bit Rate | Select between standard bit rates (5K to 1M) or use custom bit-timing |
| Enable/Disable | Individually enable/disable each CAN message |
| Identifier Customization | Individually configure CAN IDs for all messages (11-bit or 29-bit) |
| Push/Poll Mode | Individually configure 'trigger' modes for all messages (push or poll) |
| Frequency | Individually configure prescaling of the default message frequencies to lower rates |
| IMU Correction | Optionally compensate the orientation of the module as part of the IMU configuration |
| Electrical | |
|---|---|
| Input Supply | +5V to +26V DC via the DB9 connector (power via pin 1 or pin 9) |
| Alternatively power via USB (for updating firmware/config or for streaming data in real-time) | |
| Power Consumption | Extremely low (<1W) - no risk of battery drainage |
| Protection | Reverse voltage protection on CAN-bus supply |
| Transient voltage event protection on supply lines |
| Mechanical | |
|---|---|
| Enclosure & Weight | Compact aluminium enclosure: 65 x 48 x 24 mm (W x L x H excl. flanges & connectors). 70 grams |
| Connector | 1 x Standard D-Sub 9 (DB9) connector |
| Pin-Out | See the product manual for the DB9 connector pin-outs |
| USB | Standard mini USB connector for config/firmware updates and streaming (USB cable not included) |
| LEDs | Module status via 4 external LEDs: Power, CAN bus, Memory, GNSS |
| Temperature | Operating temperature (parts): -25degC to +70degC |
| IP Rating | IP Rating 40 |
| Mounting | Module can be mounted via e.g. rugged double-sided tape, zip-ties or a mounting kit |
| GPS antenna | GPS antenna included (SMA plug, 3 m cable, magnetic base) |